Montana State University · 2025
The challenge
White Lightning was a three-person engineering project to develop a compact, remotely operated racing vehicle. The team iterated through multiple mechanical prototypes. I owned the circuit design and wrote the controller firmware, using AI to help interpret documentation and ESP32 integration practices.
My contributions
System integration
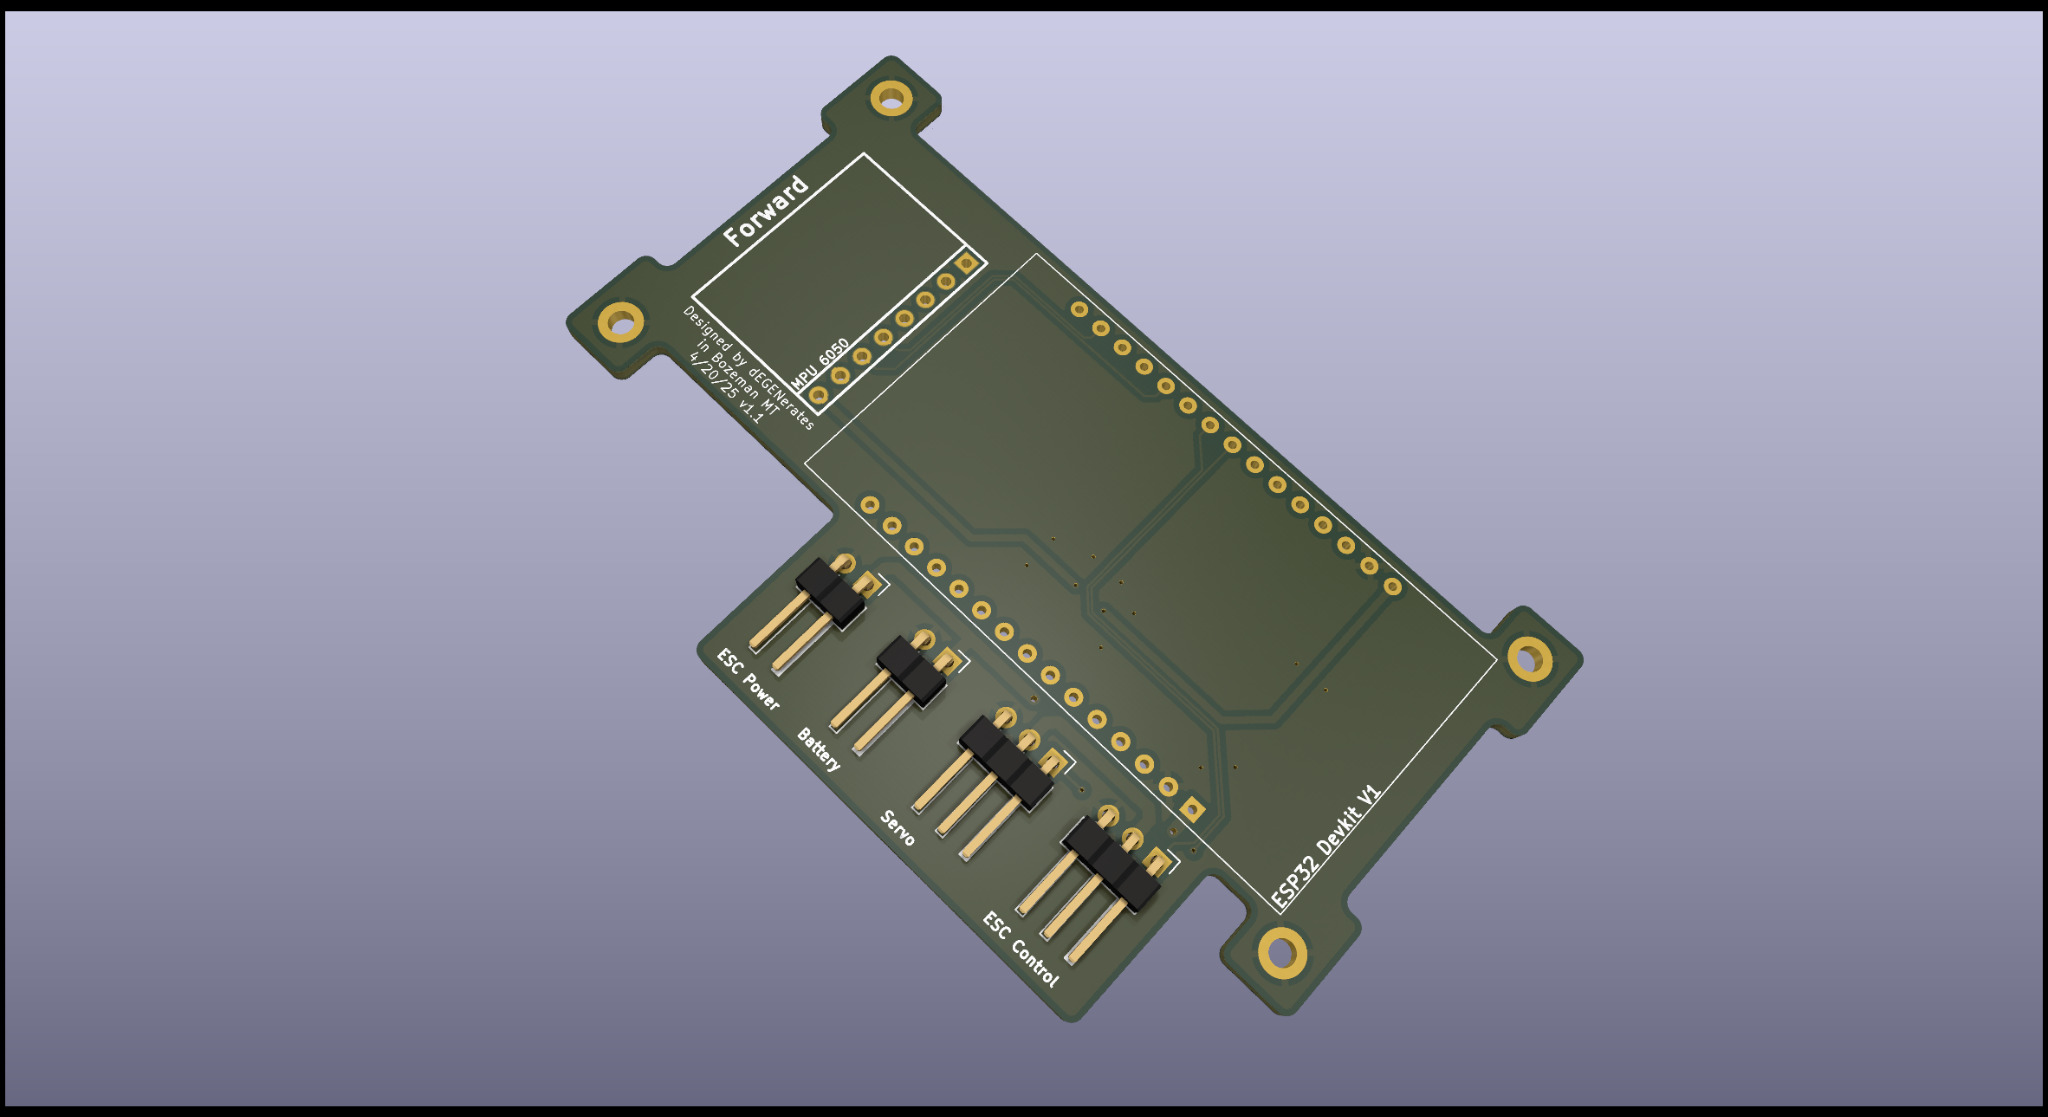
The controller uses an ESP32 development board, an MPU6050 motion-sensing module, and dedicated connectors for battery/ESC power, steering servo, and ESC commands. The board integrates existing modules; it is not a custom microcontroller design.
Control software
The Arduino/C++ controller handles gamepad connectivity and drivetrain output. IMU data is calibrated and used to modulate control commands under detected dynamic conditions. The resulting controller was tested extensively on test bench and later implemented into the chassis for further validation.
Prototyping and reflection
Vehicle testing informed revised wheel geometry, tire compound, and chassis rigidity. The project reinforced the importance of integration boundaries: mechanical design, electronics, and control software each had to work together. It also highlighted future opportunities for dedicated failsafe logic, deterministic loop scheduling, and more rigorous performance measurement.
Three-person team: Camden Roberts-Hurd (electronic design and firmware development), Christopher Jones and Samuel Smith (mechanical chassis and drivetrain development).